4DOF Spur Gear System - Eigenvalues not corresponding with the Eqns?

4 replies · 3K views · last reply
Sirsh
Messages
262
Reaction score
10
Hi there,

I am modelling a four degree of freedom system which is the dynamics of two spur gears in mesh, having two rotational and two translation degrees of freedom, respectively, a diagram exhibiting the system can be seen below.
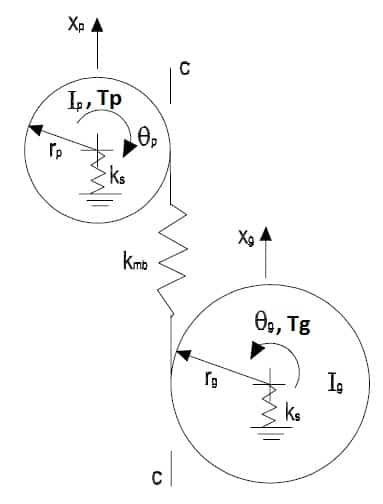
Schematic of a four degree of freedom spur gear pair, with a pinion (I_p, T_p, r_p, k_s, x_p, θ_p) and a gear (I_g, T_g, r_g, k_s, x_g, θ_g) joined by a spring labelled k_mb and cc lines marking the mesh connection.


I have derived the equations of motion (EOM) and rearranged into ODEs as seen:
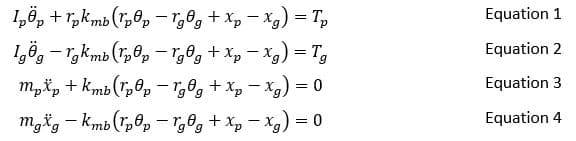
Four coupled equations of motion for a spur gear pair: pinion and gear rotational equations with torques Tp and Tg, and translational equations for the two masses with a mesh stiffness term kmb.


Where the force and torque relations are (used in the derivation process):
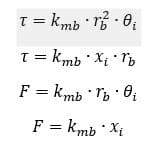
Four equations stacked vertically: torque tau = k_mb times r_b squared times theta_i; tau = k_mb times x_i times r_b; F = k_mb times r_b times theta_i; F = k_mb times x_i.

Following this I have made rewritten equations 1-4 into matrix form, creating mass and stiffness matrices.
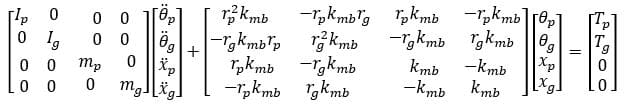
Matrix equation: a diagonal mass matrix with entries Ip, Ig, mp, mg times the acceleration vector, plus a symmetric stiffness matrix with entries built from rp, rg, kmb and the ratio of gear radii, times the displacement vector, equals the force vector Tp, Tg, 0, 0.

I have been having trouble achieving steady state of this system in my simulations using Simulink and MATLAB, so I was advised to check the eigenvalues of the dynamic matrix as well as make sure that the mass matrix is diagonal while the stiffness matrix is symmetrical - they both are.

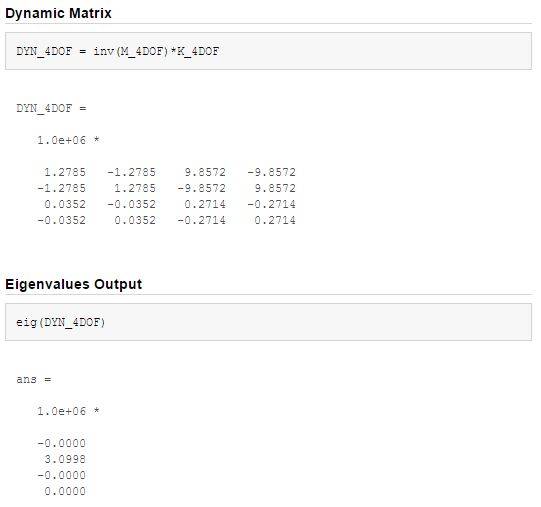
The dynamic matrix is defined as the inverse of the mass matrix multiplied by the stiffness matrix, e.g. Dyn = inv(M)*K.

Now, I have input all this into MATLAB with the corresponding values for each of the parameters. However, I can never achieve purely positive eigenvalues for this system, as I'm told is required and may be the issue with my simulation, and where if they're not all positive (including one zero) then the system of equations are incorrect. However, I have reviewed literature on spur gear dynamics and the equations are the same...

This is exhibited below as an output of my MATLAB eigenvalue calculating script:
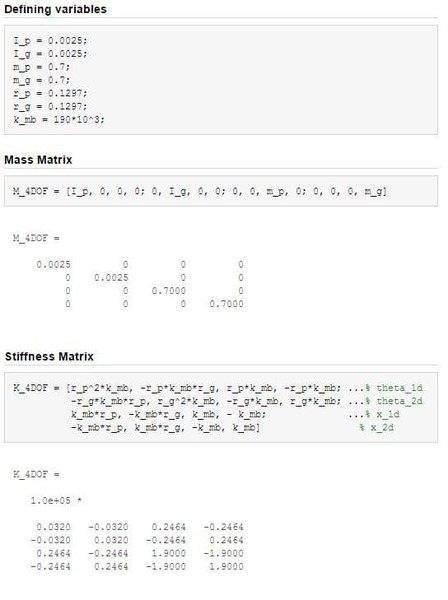
MATLAB script screenshot: defined variables I_p, I_g, m_p, m_g, r_p, r_g, k_mb, then the 4x4 mass matrix M_4DOF (diagonal) and the 4x4 stiffness matrix K_4DOF with its numeric output shown in scientific notation.

MATLAB output showing the dynamic matrix DYN_4DOF as a 4x4 numeric array of values around 1.0e+06 times 1.2785, -1.2785, 9.8572, -9.8572 and so on, followed by the eigenvalues output from eig(DYN_4DOF) listing -0.0000, 3.0998, -0.0000 and 0.0000.


Any help would be appreciated greatly, as I am an undergraduate student researching solo. So any advice on my interpretation of either the system dynamics or eigenvalue interpretation would be helpful from you all.

Thanks, Sirsh.
 
I think I can help. Let's start with the eigenvalues, which correspond to (the squares of) your modal frequencies. Since the system you have has exactly one way of moving without causing any forces (when the gears rotate opposite directions according to their gear ratio), you should have exactly one zero-frequency mode. You have three, so yes, something isn't right.

Looking at your stiffness matrix, I noticed there weren't any terms involving the addition of multiple stiffnesses. Whenever motions are coupled by springs, there will be interaction, signaled by stiffness matrix terms containing more than one stiffness.

I believe this all results from your torque and force equations. As written, you are only including the force from the deflection of the stiffness connecting the gears - only kmb appears, not either ks. You need to include the stiffnesses of your bearings; F=kx. Remember that in using F=ma, it's the resultant force applied to the mass, not just one. So each mass in your system should have a combined "bearing force" and "gear tooth" force acting on it.
 
  • Like
Likes   Reactions: John Taco and Sirsh
Randy Beikmann said:
I think I can help. Let's start with the eigenvalues, which correspond to (the squares of) your modal frequencies. Since the system you have has exactly one way of moving without causing any forces (when the gears rotate opposite directions according to their gear ratio), you should have exactly one zero-frequency mode. You have three, so yes, something isn't right.

Looking at your stiffness matrix, I noticed there weren't any terms involving the addition of multiple stiffnesses. Whenever motions are coupled by springs, there will be interaction, signaled by stiffness matrix terms containing more than one stiffness.

I believe this all results from your torque and force equations. As written, you are only including the force from the deflection of the stiffness connecting the gears - only kmb appears, not either ks. You need to include the stiffnesses of your bearings; F=kx. Remember that in using F=ma, it's the resultant force applied to the mass, not just one. So each mass in your system should have a combined "bearing force" and "gear tooth" force acting on it.

Hi Randy, thanks so much for your input!

I have updated my stiffness matrix to include the stiffness of the bearings which is now:
Four-by-four matrix with entries in r_p, r_g, k_mb, k_bp and k_bg, multiplied by a column vector of theta_p, theta_g, x_p and x_g; the diagonal entries k_mb + k_bp and k_mb + k_bg are highlighted in yellow.

And by solving the updated dynamic matrix, has yielded three purely positive eigenvalues with one zero.

So it seems like its responding as it should, now to see the simulation results!
 
By the way, you can also use Matlab to get the eigenvectors, which are the mode shapes corresponding to each modal frequency (the square root of the eigenvalues). And you can state the eigenvalue problem using the mass and stiffness matrices directly:

[V,D]=eig(K,M)

The columns of V are the eigenvectors, and the diagonal of D is the list of eigenvalues.
 
Hi,
thanks so much for sharing your answers and work.
I am analyzing this gear modeling and I have three questions:
1) I think the variables are:
Ѳ_p
Ѳ_g
x_p
x_g
T_p (torque)
T_g (torque)
There are 4 equations and 6 variables. How to solve this?
Do I have to assume values for T_p and T_q? are they equal?

2) could I assume that Ks=Kmb?

3) what are the initial values for the variables and derived variables?John Taco