Coupled pendulum-spring system

  • Thread starter Thread starter member 731016
  • Start date Start date
  • Tags Tags
    Geometric Proof
Join the discussion
Registration is free. Ask a follow-up in this thread, or start your own.
3 replies · 1K views · last reply
member 731016
Homework Statement
Please see below. I have a doubt about the solution of the problem.
Relevant Equations
Arc length = ##R\theta##
The problem and solution are,
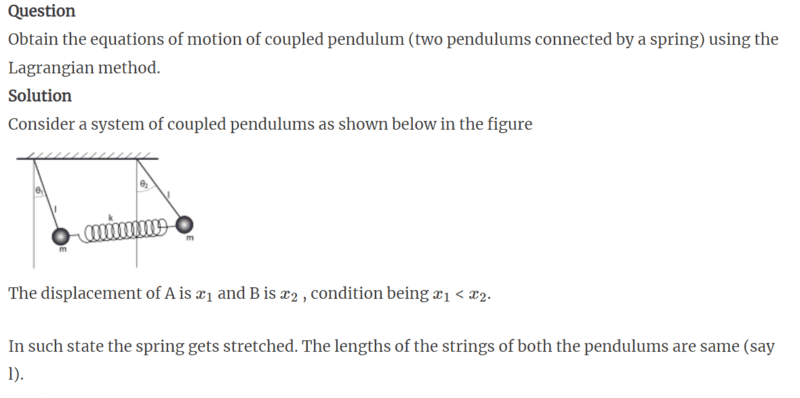
Text page showing a physics question on coupled pendulums joined by a spring, with a small diagram of two masses hanging from a ceiling, each on a string of length l, linked by a spring, and displacements x1 and x2 labelled.

Typeset text stating that the angular displacement of A is θ1 and of B is θ2 with θ2 > θ1, followed by x1 = lθ1, θ1 = x1/l (1) and x2 = lθ2, θ2 = x2/l (2).

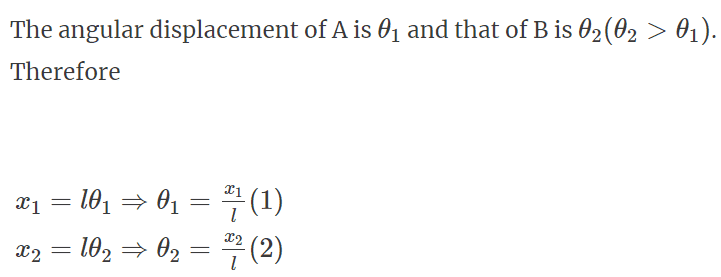
Typeset text stating that the spring's restoring force acts along the direction of displacement theta 1 and opposite to displacement theta 2, followed by the total potential energy V = mgl(1 - cos theta 1) + mgl(1 - cos theta 2) + (1/2)k(x2 - x1)^2.

However, I am confused how the separation vector between the two masses is

##\vec x = x \hat{k} = x_2 \hat{x_2} - x_1 \hat{x_1}= l\theta_2 \hat{x_2} - l\theta_1 \hat{x_1 } = l(\theta_2 - \theta_1) \hat{k}##. where I define the unit vector from mass 2 to mass 1 as ##\hat{k}## along the spring. Does someone please know of a algebraic or geometric proof for this?

Thanks a lot!
 
Physics news on Phys.org
ChiralSuperfields said:
Homework Statement: Please see below. I have a doubt about the solution of the problem.
Relevant Equations: Arc length = ##R\theta##

The problem and solution are,
View attachment 343276
View attachment 343277
View attachment 343278
However, I am confused how the separation vector between the two masses is

##\vec x = x \hat{k} = x_2 \hat{x_2} - x_1 \hat{x_1}= l\theta_2 \hat{x_2} - l\theta_1 \hat{x_1 } = l(\theta_2 - \theta_1) \hat{k}##. where I define the unit vector from mass 2 to mass 1 as ##\hat{k}## along the spring. Does someone please know of a algebraic or geometric proof for this?

Thanks a lot!
Which particular step worries you?
It seems a bit verbose to me. Why introduce ##\hat{x_2} ## and ## \hat{x_1}##? Aren’t they obviously ##\hat k## for small perturbations (compared to the length of the spring)?
 
  • Love
Likes   Reactions: member 731016
haruspex said:
Which particular step worries you?
It seems a bit verbose to me. Why introduce ##\hat{x_2} ## and ## \hat{x_1}##? Aren’t they obviously ##\hat k## for small perturbations (compared to the length of the spring)?
Thank you for your reply @haruspex!

Sorry are you saying that ##\hat{x_2} = \hat{x_1} = \hat{k}## for small ##\theta##? My confusion is how the spring displacement from equilibrium position is ##l\theta_2 - l\theta_1 = l\theta_1 - l\theta_2## since the displacement is squared. I am confused when I try to imagine subtracting two arc lengths from each other.

Thanks!
 
ChiralSuperfields said:
My confusion is how the spring displacement from equilibrium position is ##l\theta_2 - l\theta_1 = l\theta_1 - l\theta_2## since the displacement is squared. I am confused when I try to imagine subtracting two arc lengths from each other.

Thanks!
For small perturbations, the arc length is near enough the same as the displacement in the initial tangential direction, i.e. the ##\hat k## direction.
Since it is squared, it does not matter which way around you do the subtraction.
 
  • Love
Likes   Reactions: member 731016