Pendulum in accelerating car: solving motion near equilibrium

6 replies · 3K views · last reply
badluckmath
Messages
9
Reaction score
3
Homework Statement
Show that ## \omega = \frac{\sqrt{a^{2}+g^{2} }}{l} ## for small angles
Relevant Equations
After solving the Hamilton equations, we find that ## \frac{d^{2}\theta}{dt^{2}} = -gsin(\theta)/l- acos(\theta)/l ##
Here is an image of the problem:
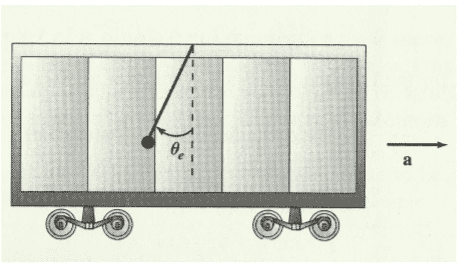
Diagram of a railway car accelerating to the right with arrow a, showing a pendulum bob hanging from the ceiling at equilibrium angle theta_e from the vertical dashed line.
The problem consist in finding the moviment equation for the pendulum using Lagrangian and Hamiltonian equations.
I managed to get the equations , which are shown insed the blue box:
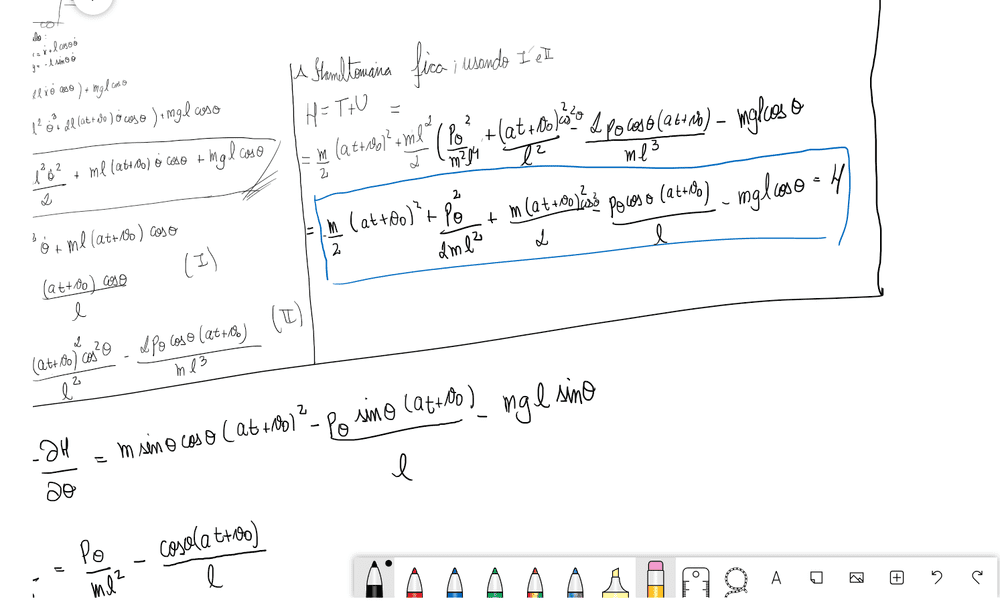
Handwritten derivation of a pendulum Hamiltonian H = T + V in a car with acceleration a, with the resulting Hamiltonian expression boxed in blue and partial derivatives with respect to theta written below.

Using the hamilton equations, i finally got that the equilibrium angle ##\theta_{e}## : $$\theta_{e} = \tan^{-1}(\frac{-a}{g})$$m which is the angle where ## \frac{d^{2}\theta}{dt^{2}} =0 ##.

Now, i got stuck. I tried to solve an EDO using the small angles aproximation, but it doesn't seems to lead me anywhere, because i don't really have information for the initial values.
 
Attachments
  • Handwritten derivation of a pendulum equation: theta double dot = -(g/l) sin(theta) - (a/l) cos(theta), rewritten as theta double dot + (g/l) theta + (a/l) = 0 with w0^2 = g/l and w1^2 = a/l, then theta = w1^2/w0^2 + A sin(w0 t) + B cos(w0 t) and its first and second derivatives.
    Sem título.png
    27.2 KB · Views: 264
  • Like
Likes   Reactions: kent davidge
You want small angles wrt ##\theta_e##, so work the equation around to ##\theta' = \theta -\theta_e## in first order of ##\theta'##.
 
Did you understand my post at all ? You want to work with ##\theta'##, not with ##y## .
 
BvU said:
Did you understand my post at all ? You want to work with θ′, not with y .
This was another question. About your answer, i used ## \mu = \theta + \theta_{e}## and i got the right answer. Which is the same as you said.
 
badluckmath said:
This was another question.
And do we have a problem statement for that one ?

Side note: use \cos and \sin, just like \tan.
That way there is no confusion about e.g.
## acos(\theta)/l## read as ## \operatorname {acos}(\theta)/l## instead of ## a\cos(\theta)/l##
 
BvU said:
And do we have a problem statement for that one ?

Side note: use \cos and \sin, just like \tan.
That way there is no confusion about e.g.
## acos(\theta)/l## read as ## \operatorname {acos}(\theta)/l## instead of ## a\cos(\theta)/l##
It's the same as before, but now, the acceleration is upwards .
 
Thread now looks garbled: there was a post #3 from you that has disappeared :oldconfused:
(not so bad, it was barely legible :nb) )