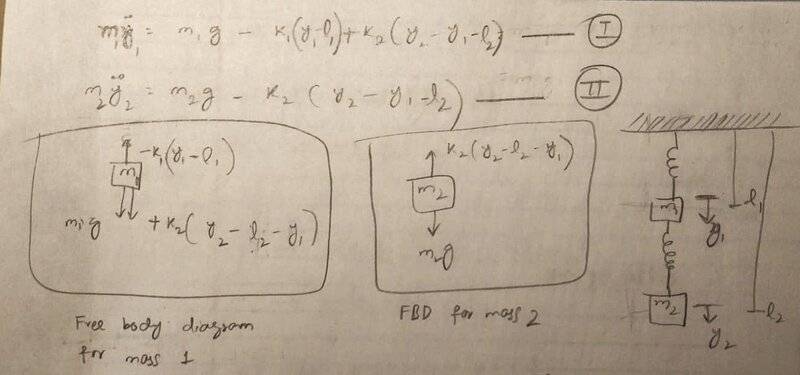Coupled Vertical Spring-Mass Systems

3 replies · 4K views · last reply
graviton_10
Messages
5
Reaction score
1
Homework Statement
A vertical spring mass system is attached in series with another vertical spring mass system. Masses of both objects are different and so are the spring constants of both springs. y1 and y2 are the coordinates measured from the rest position of mass 1 and mass 2 respectively.

I have identified the forces on both masses using free body diagram, but I do not know how to proceed next.
My final goal is to set up matrix equation and then solve for normal frequencies.
Relevant Equations
Mq'' = Kq
How should I proceed?
Handwritten notes with two equations of motion for coupled masses, free body diagrams for mass 1 and mass 2, and a diagram of two masses hanging from a ceiling on springs.
 
Last edited by a moderator:
I'm getting ##\downarrow^+##:

$$m_1 \ddot y_1 = m_1 g - k_1( y_1 - l_1) + k_2 \Big[ (l_2 + y_2) - (l_1 + y_1) \Big]$$

$$m_2 \ddot y_2 = m_2 g - k_2 \Big[ (l_2 + y_2) - (l_1 + y_1) \Big]$$
 
As for solving the system, another option is to solve a single fourth order ODE by either solving ##y_1## in terms of ##y_2## and computing ##\ddot y_1## or visa-versa.
 
Actually, I blundered too.

Diagram of two vertical springs in series hanging from a ceiling with masses m1 and m2, shown in equilibrium on the left and displaced on the right. Labels l1, l2, y1, y2, Δy1 and Δy2 mark lengths and displacements.


Let ##l_1## and ##l_2## be the unloaded free lengths of the springs. The equation for static equilibrium ( LHS of the diagram)

$$ m_1 g - k_1( y_1 - l_1) + k_2( y_2 - l_2) = 0 \tag{1} $$

$$ m_2 g - k_2( y_2 - l_2 ) = 0 \tag{2}$$

Now, displace ##m_1, m_2## from equilibrium by some distance ## \Delta y_1, \Delta y_2## respectively. What follows is that:

$$ m_1 \ddot{\Delta y_1} = m_1 g - k_1( y_1 + \Delta y_1 - l_1 )+ k_2( y_2 + \Delta y_2 - \Delta y_1 - l_2) \tag{3}$$

Now, expand (3) as follows:

$$ m_1 \ddot{\Delta y_1} = \cancel{ \boxed{m_1 g - k_1( y_1 - l_1) + k_2( y_ 2 - l_2)}}^0 -k_1 \Delta y_1 + k_2( \Delta y_2 - \Delta y_1)$$

Notice the boxed terms are identically 0 by (1). It follows that:

$$ m_1 \ddot{\Delta y_1} = -k_1 \Delta y_1 + k_2( \Delta y_2 - \Delta y_1) \tag{4}$$

I'll let you determine the result for ##m_2##.
 
Last edited: