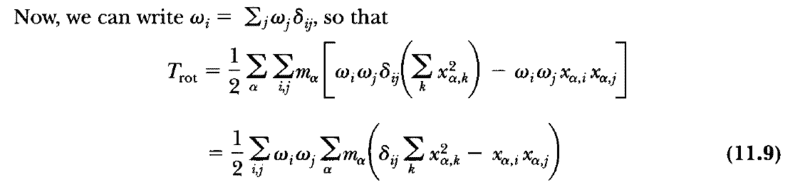Questions Regarding the Inertia Tensor

Join the discussion
Registration is free. Start your own thread to ask a follow-up.
3 replies · 3K views · last reply
sams
Gold Member
Messages
84
Reaction score
2
In Chapter 11: Dynamics of Rigid Bodies, in the Classical Dynamics of Particles and Systems book by Thornton and Marion, Fifth Edition, pages 415-418, Section 11.3 - Inertia Tensor, I have three questions regarding the Inertia Tensor:

1.The authors made the following statement: "neither V nor ω is characteristic of the αth particle."
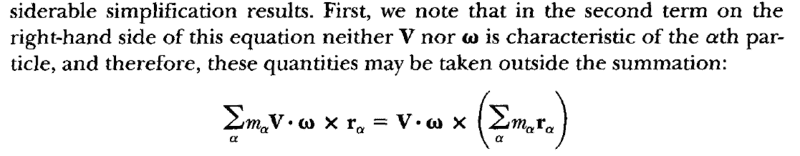
Printed textbook passage with the equation sum over alpha of m_alpha V dot omega cross r_alpha equals V dot omega cross (sum over alpha of m_alpha r_alpha), simplifying a term in rigid body dynamics.

What do the authors mean by the above statement and how did they take V.ω outside the relation?

2. Kronecker delta function
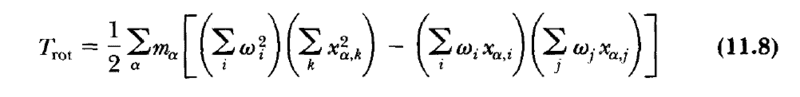
Equation 11.8: T_rot = (1/2) sum over alpha of m_alpha times [ (sum over i of omega_i squared)(sum over k of x_alpha,k squared) minus (sum over i of omega_i x_alpha,i)(sum over j of omega_j x_alpha,j) ].

Handwritten-style typeset derivation of rotational kinetic energy T_rot = (1/2) sum over alpha and i,j of m_alpha [w_i w_j delta_ij (sum_k x_alpha,k^2) - w_i w_j x_alpha,i x_alpha,j], rewritten as (1/2) sum_ij w_i w_j sum_alpha m_alpha (delta_ij sum_k x_alpha,k^2 - x_alpha,i x_alpha,j), labelled equation (11.9).


Shouldn't the second term in the square brackets or in the parenthesis of Equation (11.9) also contain the Kronecker delta function?

3. Physical Interpretation of the diagonals and off-diagonals of the Inertia Tensor
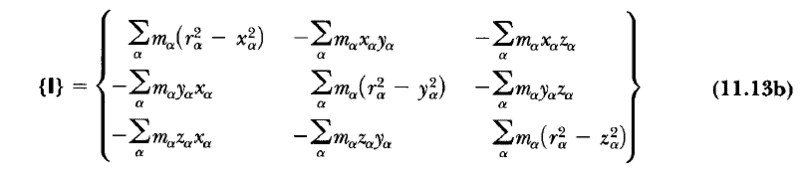
Equation 11.13b: the inertia tensor {I} as a 3 by 3 matrix. Diagonal entries are sums over alpha of m_alpha(r_alpha^2 - x_alpha^2), m_alpha(r_alpha^2 - y_alpha^2) and m_alpha(r_alpha^2 - z_alpha^2). Off-diagonal entries are negative sums of m_alpha x_alpha y_alpha, m_alpha x_alpha z_alpha and m_alpha y_alpha z_alpha.


According to the authors, the diagonal terms are called the moments of inertia and the off-diagonal terms are called the products of inertia. What are the physical interpretations of the diagonal and the off-diagonal terms? What is the difference between them?

Thank you so much for your help.
 
Attachments
  • Printed textbook passage with the equation sum over alpha of m_alpha V dot omega cross r_alpha equals V dot omega cross (sum over alpha of m_alpha r_alpha), simplifying a term in rigid body dynamics.
    1.PNG
    13.6 KB · Views: 574
  • Equation 11.8: T_rot = (1/2) sum over alpha of m_alpha times [ (sum over i of omega_i squared)(sum over k of x_alpha,k squared) minus (sum over i of omega_i x_alpha,i)(sum over j of omega_j x_alpha,j) ].
    2.PNG
    6.2 KB · Views: 524
  • Handwritten-style typeset derivation of rotational kinetic energy T_rot = (1/2) sum over alpha and i,j of m_alpha [w_i w_j delta_ij (sum_k x_alpha,k^2) - w_i w_j x_alpha,i x_alpha,j], rewritten as (1/2) sum_ij w_i w_j sum_alpha m_alpha (delta_ij sum_k x_alpha,k^2 - x_alpha,i x_alpha,j), labelled equation (11.9).
    3.PNG
    8 KB · Views: 607
  • Inertia tensor matrix {I} as a 3x3 array: diagonal entries sum m_alpha(r_alpha^2 - x_alpha^2), sum m_alpha(r_alpha^2 - y_alpha^2), sum m_alpha(r_alpha^2 - z_alpha^2); off-diagonal entries negative sums of m_alpha x_alpha y_alpha, and so on. Equation 11.13b.
    4.PNG
    7.6 KB · Views: 443
  • Equation 11.13b: the inertia tensor {I} as a 3 by 3 matrix. Diagonal entries are sums over alpha of m_alpha(r_alpha^2 - x_alpha^2), m_alpha(r_alpha^2 - y_alpha^2) and m_alpha(r_alpha^2 - z_alpha^2). Off-diagonal entries are negative sums of m_alpha x_alpha y_alpha, m_alpha x_alpha z_alpha and m_alpha y_alpha z_alpha.
    4.PNG
    7.6 KB · Views: 542
Last edited:
Physics news on Phys.org
sams said:
What do the authors mean by the above statement and how did they take V.ω outside the relation?
They mean that all particles have the same V and the same ω, so they can be taken out of the summation, due to the distributive property of the cross product.

sams said:
Shouldn't the second term in the square brackets or in the parenthesis of Equation (11.9) also contain the Kronecker delta function?
No, since the second term comes from a double sum over the components of ω and x. The Kronecker delta is introduced to transform the single sum into a double sum, so that both terms can be written together as a double sum.

sams said:
According to the authors, the diagonal terms are called the moments of inertia and the off-diagonal terms are called the products of inertia. What are the physical interpretations of the diagonal and the off-diagonal terms? What is the difference between them?
There is an orthogonal system of coordinates in which the tensor of inertia is diagonal. In that case, the moments of inertia obtained are aligned with the coordinate axes and they are called the principal moments of inertia. They represent the "natural" way in which the body can rotate. Any rotation can be written as a superposition of rotations around the principal moments of inertia.
 
  • Like
Likes   Reactions: sams
DrClaude said:
No, since the second term comes from a double sum over the components of ω and x. The Kronecker delta is introduced to transform the single sum into a double sum, so that both terms can be written together as a double sum.
Equation (11.7): T_rot = (1/2) sum over alpha of m_alpha [omega^2 r_alpha^2 - (omega . r_alpha)^2], rotational kinetic energy of a rigid body.

Equation (11.8) is obtained from Equation (11.7). How did the second term come with a double sum and not the first term as well?
 
Attachments
  • Equation (11.7): T_rot = (1/2) sum over alpha of m_alpha [omega^2 r_alpha^2 - (omega . r_alpha)^2], rotational kinetic energy of a rigid body.
    5.PNG
    1.4 KB · Views: 485
sams said:
How did the second term come with a double sum and not the first term as well?
Because you are squaring a dot product. The dot product will give you a sum of three terms, and when you square it you get a product of two sums.

I suggest you write it out. It takes only a couple of lines, and it is just simple vector algebra. All will then become clear.