Problems in understanding kinematics

  • Thread starter Thread starter arifle
  • Start date Start date
  • Tags Tags
    Kinematics
Join the discussion
Registration is free. Start your own thread to ask a follow-up.
2 replies · 2K views · last reply
arifle
Messages
2
Reaction score
0
TL;DR
wheeled robot kinematics and constraints
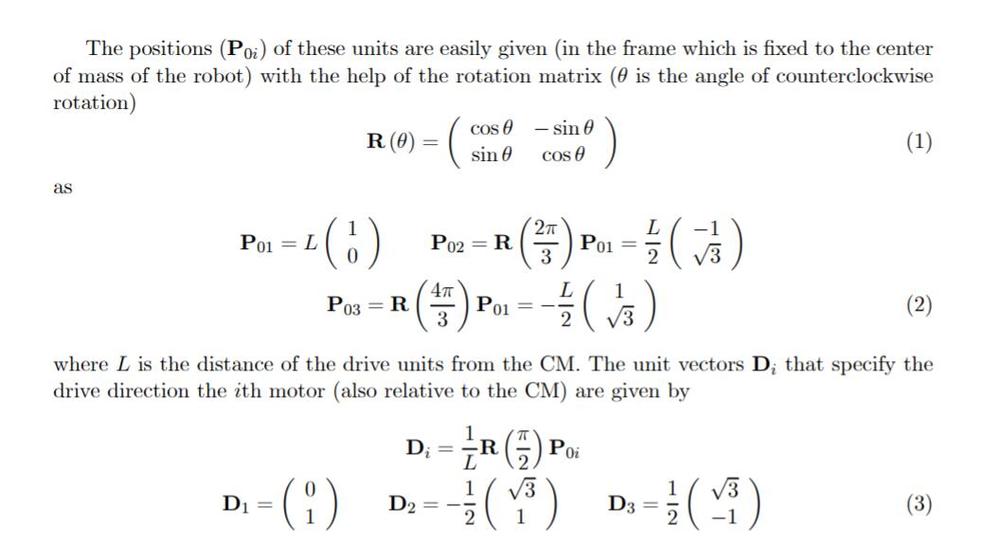
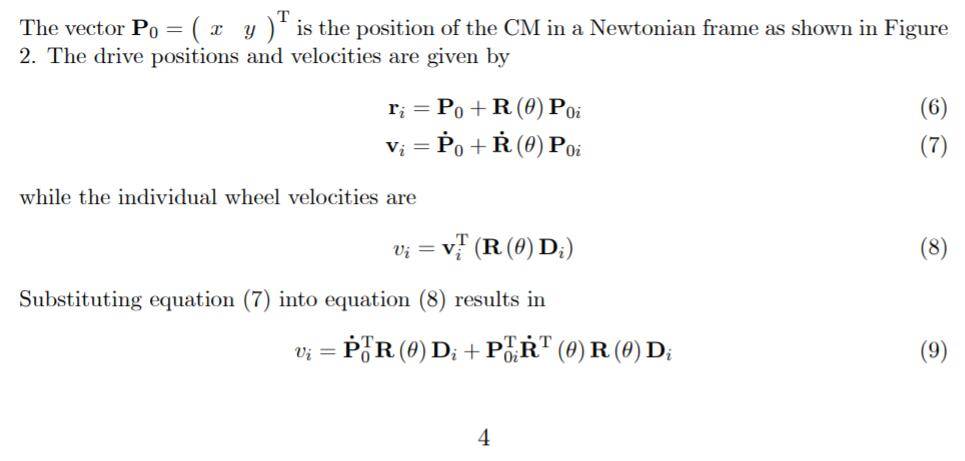
Hi, I tried to understand kinematics after having an omnidirectional roobt. Some problems stop me to go further. Here I upload some contents of different papers talking about kinematics. For the 1st three pictures, I don't know how equation (8) is from and I am little confused about translational and tangentianal velocities. I don't know why it mutiplys R(theta) again in equation (8).
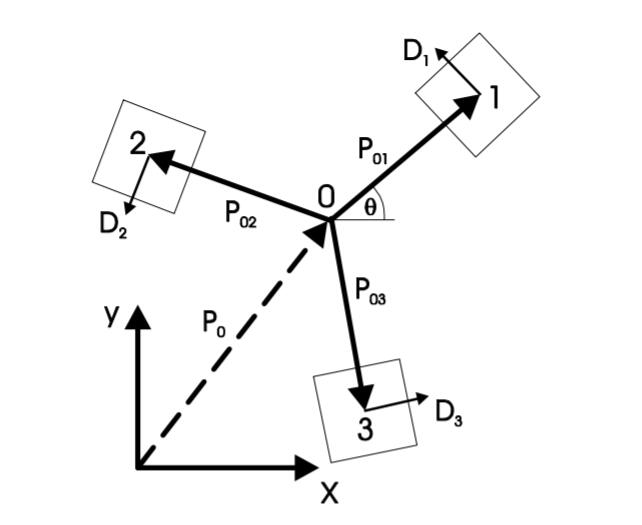
Diagram of a three-wheeled omnidirectional robot: central point O with position vector P0 from the origin of the x-y frame, and arms P01, P02, P03 to wheels 1, 2 and 3, with wheel drive directions D1, D2, D3 and angle theta measured from the horizontal at O.

Typeset equations defining positions P01, P02, P03 of drive units via rotation matrix R(theta), with L as distance from center of mass, and drive unit vectors D1, D2, D3.
Typeset equations from a kinematics paper: position of the centre of mass P0 = (x y)^T, drive positions r_i = P0 + R(theta) P0i, velocities, wheel speed v_i = v_i^T(R(theta) D_i), and expanded form (9).

For the 2nd paper, I cannot obtain the equation of v_trans,i. Also, I am not sure if the rotation matrix in this case is R(theta) = [cos(theta) -sin(theta); sin(theta) cos(theta)]. Can anyone please tell some details about the kinematics.
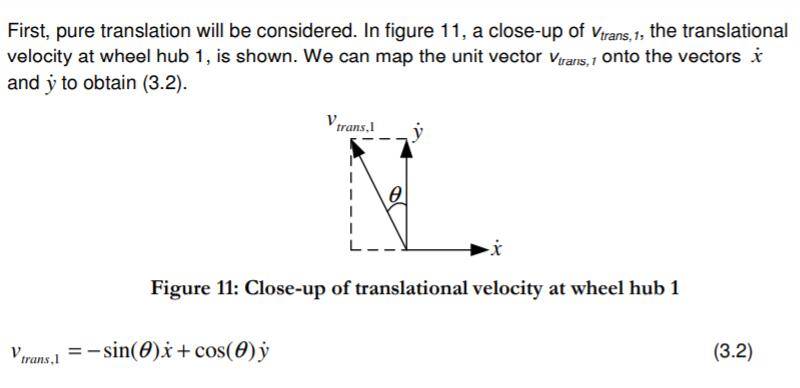
Vector diagram of translational velocity at wheel hub 1: vector v_trans,1 at angle theta from the y-dot axis, with dashed components along x-dot and y-dot. Equation v_trans,1 = -sin(theta) x-dot + cos(theta) y-dot (3.2).

At last, there is another lecture about kinematics. The problem is still about the constraints. How can I derive this pure rolling constraint.
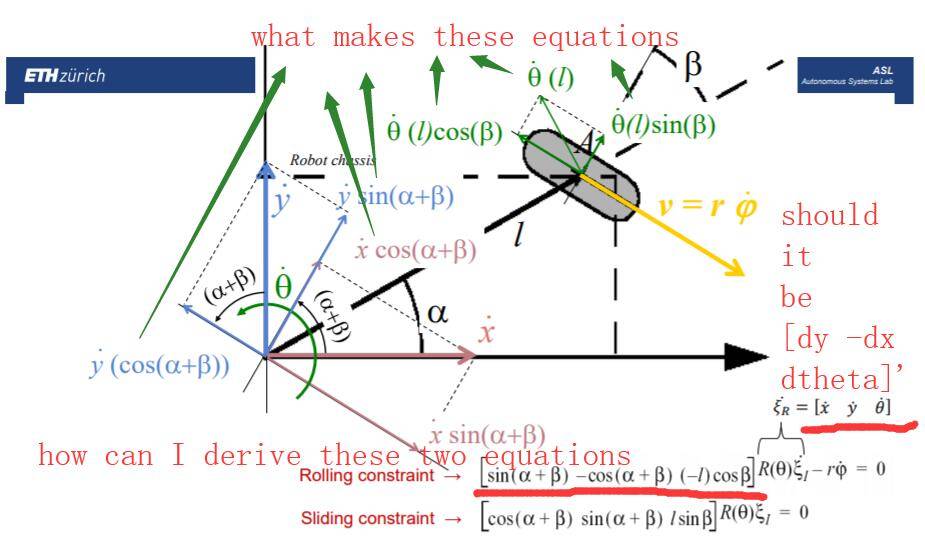
Diagram of a wheeled robot chassis with the robot's frame angle theta, wheel offset l and angle beta, showing velocity components x dot, y dot and theta dot. Below are the rolling and sliding constraint matrix equations involving R(theta) and the pose vector.
 
Physics news on Phys.org
It looks to me as though equation (8) in the first paper is the dot product of the drive velocity with the direction vector of the drive's wheel, i.e. the component of the velocity in the direction of the wheel spins. I guess that would imply that the wheel is also sliding sideways. If ##\theta## is a function of time, then the extra multiplication by ##\mathbf R(\theta(t))## would give the direction of the wheel at time ##t##.
 
tnich said:
It looks to me as though equation (8) in the first paper is the dot product of the drive velocity with the direction vector of the drive's wheel, i.e. the component of the velocity in the direction of the wheel spins. I guess that would imply that the wheel is also sliding sideways. If ##\theta## is a function of time, then the extra multiplication by ##\mathbf R(\theta(t))## would give the direction of the wheel at time ##t##.
Thank you, tnich. How can we get the equation of the rolling constraint if we focus on the 3rd approach.