A simple problem just for fun

  • Level: Undergrad 
  • Thread starter Thread starter wrobel
  • Start date Start date
Join the discussion
Registration is free. Ask a follow-up in this thread, or start your own.
22 replies · 1K views
Science Advisor
Insights Author
Messages
1,418
Reaction score
1,171
A uniform massive cylinder is free to rotate about its fixed horizontal axis. A uniform disk of smaller radius rolls without slipping along the inner surface of the cylinder. The system is in the uniform gravitational field g. Prove that any motion of the system starting from rest is periodic or an equilibrium.
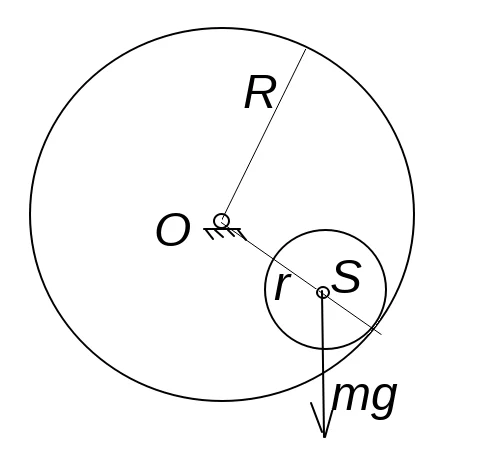
1.webp
 
Last edited:
Physics news on Phys.org
So the fixed horizontal axis supports the outer cylinder against the "uniform gravitational field". The inner cylinder must be supported by a "sticky" contact with the large cylinder?
The system is put into motion by pushing the outer cylinder, the inner cylinder, or both?

It seems to me that the gravitational field serves no real purpose. As long as there is a way to "fix" the axis, the experiment could be done in free fall.
 
wrobel said:
A uniform disk of smaller radius rolls without slipping along the inner surface of the cylinder.
Does the disk have a finite thickness, volume, mass and inertia?

Is the disk constrained to remain in a plane orthogonal to the cylinder axis, or can it fall onto one side and so stop rolling, then just flip heads and tails?
 
I believe that rolling without slipping means there is no loss so energy and momentum are conserved. If you start it from rest as in the picture, this system is a clock. However, if in equilibrium at the lowest point and you slowly move the big cylinder, the bottom disk will stay at the bottom maintaining the equilibrium I think.
 
wrobel said:
A uniform disk of smaller radius rolls without slipping along the inner surface of the cylinder.
"Along" the cylinder's length, helical, or along an inner circumference.
If the disk became a short cylindrical roller, it might restrict the question.
 
Here is my conception of the motion. The angles are measured from the vertical axis. The small disk is ##\theta## and the cylinder is ##\phi##. I chose positive angles to the right and positive angular velocities the sense they would have at ##t=0## which is swinging to the left. In this scenario we gently roll the disk from its position at the bottom at rest to the position at ##t=0##.

IMG_6707.webp
 
As far as proof goes, if we write the Lagrangian it will be a complicated expression of the masses, radii, angles ##\theta## and ##\phi##. But the angles are related through the no-slip condition so we really only end up with one variable, say ##\theta## and the equation of motion will just be an equation of harmonic motion because all the forces are non-dissipative it can be reduced to $$\ddot{\theta} + \omega_0^2 \sin(\theta) = 0$$
where ##\omega_0^2## is some complicated function of the problem parameters.
 
I describe the cylinder rotation with a phasor. Since the cylinder is massive, there can be no step function in the cylinder rotation. The disk can roll, has inertia, so will swing like a pendulum. Take the Fourier Transform of the cylinder phasor and multiply it by the FT of the disk pendulum. Inverse FT that product to get the disk position in time. Since the result is represented by a FT, the result must be periodic or an equilibrium.
 
wrobel said:
The system has two degrees of freedom
But they can be expressed in one equation of motion because of the constraint of the no-slip condition as above when starting from rest. Are you looking for a complete mathematical solution?
 
I am imagining a physical setup where the wheels are engaged in their no-slip contact while we physically pull the wheel up the side of the cylinder to set up the starting position as in post #7.
 
wrobel said:
Prove that any motion of the system starting from rest is periodic or an equilibrium.
Say contact and no slippery condition holds, initial condition matters with periodicity ?
1792795455005.webp
 
Last edited:
If we let ##\theta## and ##\phi## be angles measured from the vertical of the wheel (disk) and the cylinder about the axis of the cylinder, and ##\psi## be the angle of the wheel about its center we have;

##K = \frac{1}{2}m(R-r)^2\dot{\theta}^2 + \frac{1}{2}I_w\dot{\psi}^2 + \frac{1}{2}I_c\dot{\phi}^2##

Because the contact point has the same velocity:

##\large\dot{\psi} = \frac{R}{r}\dot{\phi} - \frac{(R-r)}{r}\dot{\theta}##

so

##K = \frac{1}{2}I_c\dot{\phi}^2 + \frac{1}{2}m(R-r)^2\dot{\theta}^2 + \frac{1}{2}I_w\left(\frac{R\dot{\phi} - (R-r)\dot{\theta}}{r}\right)^2##

##U = mg(R-r)(1-\cos\theta)## then

##L = K - U##

Using the Euler-Lagrange equations;

##\large\frac{d}{dt}\left(\frac{\partial L}{\partial \dot{q}_i}\right) - \frac{\partial L}{\partial q_i} = 0 ;## ##q_1=\phi##, ##q_2=\theta##


Evaluating for ##\phi ## gives:

##\large\ddot{\phi} = \left[\frac{I_w R(R-r)}{I_c r^2 + I_w R^2}\right] \ddot{\theta}##

for ##\theta ##;

##\large\left[m(R-r) + I_w \frac{R-r}{r^2}\right]\ddot{\theta} - I_w \frac{R}{r^2}\ddot{\phi} + mg\sin\theta = 0##

Combining the two equations yields;

##\large(R-r)\left[m+\frac{I_{w}I_{c}}{I_{c}r^{2}+I_{w}R^{2}}\right]\ddot{\theta }+mg\sin \theta =0##

With

##\omega _{0}=\Large\sqrt{\frac{mg}{(R-r)\left[m+\frac{I_{w}I_{c}}{I_{c}r^{2}+I_{w}R^{2}}\right]}}##

Which is just a harmonic equation;

##\large\ddot{\theta}+\omega_{0}^2\sin\theta=0##

For the equilibrium “any motion of the system starting from rest is periodic or an equilibrium” part, if we use


##\large\dot{\psi} = \frac{R}{r}\dot{\phi} - \frac{(R-r)}{r}\dot{\theta}##

Let ##\dot{\theta}## be zero, meaning it stays at the lowest point, then;


##\large\dot{\psi} = \frac{R}{r}\dot{\phi}##

So the system stays in the same relative position with the disk spinning at the lowest point as the cylinder turns.
 
Last edited:
wrobel said:
The system has two degrees of freedom
Just like a double pendulum, and yet it's periodic and not chaotic. Comparing the two might be educating.
 
A.T. said:
Just like a double pendulum, and yet it's periodic and not chaotic.
Assuming two degrees of freedom, that the two axes are fixed in separation, as in post #14.
Without that it could be chaotic, should the axis of the disk rise above the axis of the cylinder, the disk will fall away from the surface of the cylinder, introducing a period of disconnect, followed by an instant when the disk shares its previous angular momentum, with the new angular position of the cylinder, applied at the point it lands.
 
Baluncore said:
Assuming two degrees of freedom, that the two axes are fixed in separation, as in post #14.
Yes, I'm talking about the variant in post #14. It has 3 rotational joints which are kinematically constrained, such that it reduces to 2 independent degrees of freedom. Yielding periodic motion.

While a double pendulum has 2 rotational joints without kinematic constraints, also resulting in 2 independent degrees of freedom. Yielding chaotic motion.

Is there a general method to predict periodic vs. chaotic motion without solving the equations of motion?
 
Last edited:
A.T. said:
Yes, I'm talking about the variant in post #14. It has 3 rotational joints which are kinematically constrained, such that it reduces to 2 independent degrees of freedom. Yielding periodic motion.

While a double pendulum has 2 rotational joints without kinematic constraints, also resulting in 2 independent degrees of freedom. Yielding chaotic motion.

Is there a general method to predict periodic vs. chaotic motion without solving the equations of motion?
One difference between the two cases is, that for the chaotic double pendulum gravity can excert a torque about both rotational joints, while for the periodic case in post #14 gravity can excert a torque only around one rotational joint, like for a simple pendulum.

Is that the reason for the different behaviors?
 
Chaos is an informal umbrella term for a broad spectrum of fundamentally distinct dynamical phenomena that manifest in the complex behavior of trajectories within a dynamical system. Both what constitutes 'complex behavior' and how 'chaos' is defined must be rigorously specified in each case; otherwise, any discussion of chaos becomes meaningless. Regrettably, such amateurish and speculative remarks are widespread.
 
Last edited:
wrobel said:
how 'chaos' is defined must be strictly formulated in every instance
Non-periodical in this case.
 
It is a fun problem! It is also interesting to consider different limiting cases. For example if the cylinder is very massive one can treat it like a fixed curved track in the limiting case. Or if one considers the disk a point mass at ##R## from the center of the cylinder held by static friction the system acts like one imbalanced wheel.