Understanding and Tuning Non-Linear PID Controllers for UAVs

3 replies · 2K views · last reply
young_penguin
Messages
2
Reaction score
0
TL;DR
NLPID and LPID
Hello,
I'm working on a project controlling a UAV (quadcopter)
I'm trying to understand non-linear PID controllers.
I know that a linear PID is given by:
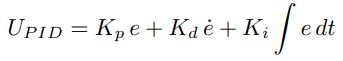
Equation for a linear PID controller output: U_PID = K_p e + K_d de/dt + K_i integral of e dt, with constant gains K_p, K_d and K_i.

and a non-linear PID the konstant terms are replaced with functions
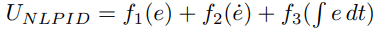
Equation: U_NLPID = f1(e) + f2(ė) + f3(∫ e dt), a non-linear PID control law with each term a function of error, its derivative or its integral.

My question is: how to i find these function and tune the paremeters, i don't seem to understand
Hope someone can help!
 
Hello young penguin, :welcome:

Don't the authors describe that in their paper ?

Typeset equation (6) defining a non-linear PID control law: U_NLPID = f1(e) + f2(de/dt) + f3(integral of e dt), with f_i(beta) = k_i(beta)|beta|^alpha_i sign(beta) and k_i(beta) = k_i1 + k_i2 / (1 + exp(mu_i beta^2)), for i = 1, 2, 3.

You can hardly expect us to do much better on such a general question than a paper (probably the same as the one you looked at) of 10 pages with 32 references.
 
young_penguin said:
I haven't seen this paper
So where did your formula picture come from ?
young_penguin said:
i don't seem to understand what f_z1, f_z2, and f_z3 are.
I suppose I could read the paper thoroughly and come up with an answer. But I am certain you can read too :smile:
 
BvU said:
Hello young penguin, :welcome:

Don't the authors describe that in their paper ?

View attachment 256188
You can hardly expect us to do much better on such a general question than a paper (probably the same as the one you looked at) of 10 pages with 32 references.

Hello BvU
Sorry i was a little too fast, i was reading the paper.
thanks for the reply. I have looked at the paper you link to, and have some basic questions i hope you can answer for me.

I don't seem to understand how the coefficients k_i1, k_i2, mu and alpha are found
I see what he says in section 5.1. Step reference tracking but i don't understand it.
Hope you can help
Equation (25): find gain vector Gamma = [Gamma_x, Gamma_y, Gamma_z, Gamma_phi, Gamma_theta, Gamma_psi] which minimizes OPI, where opi_i = w_1i x ITAE_i/N_1i + w_2i x USQR_i/N_2i and OPI = sum over i of (w_i hat x iopi_i), i = x, y, z, psi.

Two equations from a paper: where Γσ = [k11 k12 k21 k22 k31 k32 μ1 μ2 μ3 α1 α2 α3] with σ = {x, y, z, φ, θ, ψ}; and for the LPID controller, Find Γ = [Γx, Γy, Γz, Γφ, Γθ, Γψ] which minimizes (25) where Γσ = [Kp Kd Ki].