Forward kinematics of a snake robot

7 replies · 2K views · last reply
chaker
Messages
3
Reaction score
0
i want to build a forward kinematic model of a snake robot, to find its end-effector position

am already worked on a few robotic arms like puma 560 using the DH table
so i tried using the DH table on the snake robot, but it seemed wrong, so how do i do it ?

the snake robot is similar to the picture below
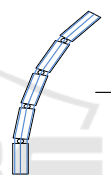
Diagram of a segmented snake robot drawn as a chain of rectangular links joined by small circular joints, curving from a flat base at the bottom to an angled tip at the top.
 
Welcome to PF.
How many segments do you use ?
What mode of movement do you model ?
What degree of freedom do the joints have ?
On a flat surface a snake moves by lifting loops from the surface, then passing the loops forwards.
 
Baluncore said:
Welcome to PF.
How many segments do you use ?
What mode of movement do you model ?
What degree of freedom do the joints have ?
On a flat surface a snake moves by lifting loops from the surface, then passing the loops forwards.
Two-column table of robot specifications: Weight ~550 g; Width/height 90 mm; Length between joint axes 210 mm; Degrees of freedom 1; Max joint travel ±90°; Max continuous joint torque 3.0 Nm at 12 V; Max joint speed with no load 77 RPM at 12 V.

these are the parameters i have
also i only worked on simple articulated robotic arms so i have no idea about this kind of robots and am trying to learn it
the example am working on is from an article called "The Redesigned Serpens, a Low-Cost, Highly Compliant Snake Robot " which can be found as pdf on google
 
First understand two of the ways that a 1 DoF model snake travels.
1. With hinge pins vertical, it “swims”, by pushing on fixed things in the environment, or:
2. With hinge pins horizontal, it lifts a 3 segment loop at the tail, so tip of the tail comes forwards, then that loop travels forwards like a ripple along the snake.
In both cases, if it has sufficient segments there can be several push points or active loops.
How can a square section snake, with a 1 DoF hinge, roll on it's side ?
Will your "kinematic model" be in software or hardware ?
Do you have a simulator ?
Have you watched snakes moving in different environments ?
 
am working on MATLAB with peter corke robotic toolbox
i wanted to start with simple movement.
 
Here are the basic methods of moving.

You need to consider what degrees of freedom you require to make a simple but useful movement.