deuteron
- 64
- 14
- TL;DR
- why are the gradients of the holonomic constraints perpendicular to the constraint forces
My question is about the general relationship between the constraint functions and the constraint forces, but I found it easier to explain my problem over the example of a double pendulum:
Consider a double pendulum with the generalized coordinates ##q=\{l_1,\theta_1,l_2,\theta_2\}##,:
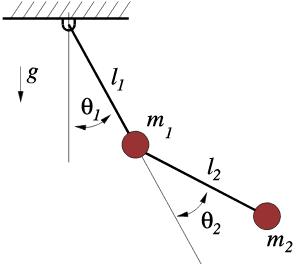
The set of constraint functions is:
$$f=\begin{pmatrix} l_1-\text{const.}_1\\ l_2-\text{const.}_2\end{pmatrix}=0$$
Since ##f=0## describes the level curve ##N_0(f)##, it describes a submanifold in the configuration space, the generalized coordinates of phase space
Since this is a level curve, ##\nabla f## is perpendicular to the manifold embedded in the configuration space
However, the constraint *forces* act on the physical plane of motion, which is a submanifold in ##3d## space
Therefore, I don't understand how we can say that ##\nabla f\| F_\text{constraint}## in the Lagrangian mechanics, since they act on manifolds embedded in different spaces
Consider a double pendulum with the generalized coordinates ##q=\{l_1,\theta_1,l_2,\theta_2\}##,:
The set of constraint functions is:
$$f=\begin{pmatrix} l_1-\text{const.}_1\\ l_2-\text{const.}_2\end{pmatrix}=0$$
Since ##f=0## describes the level curve ##N_0(f)##, it describes a submanifold in the configuration space, the generalized coordinates of phase space
Since this is a level curve, ##\nabla f## is perpendicular to the manifold embedded in the configuration space
However, the constraint *forces* act on the physical plane of motion, which is a submanifold in ##3d## space
Therefore, I don't understand how we can say that ##\nabla f\| F_\text{constraint}## in the Lagrangian mechanics, since they act on manifolds embedded in different spaces